Open source
Medkit
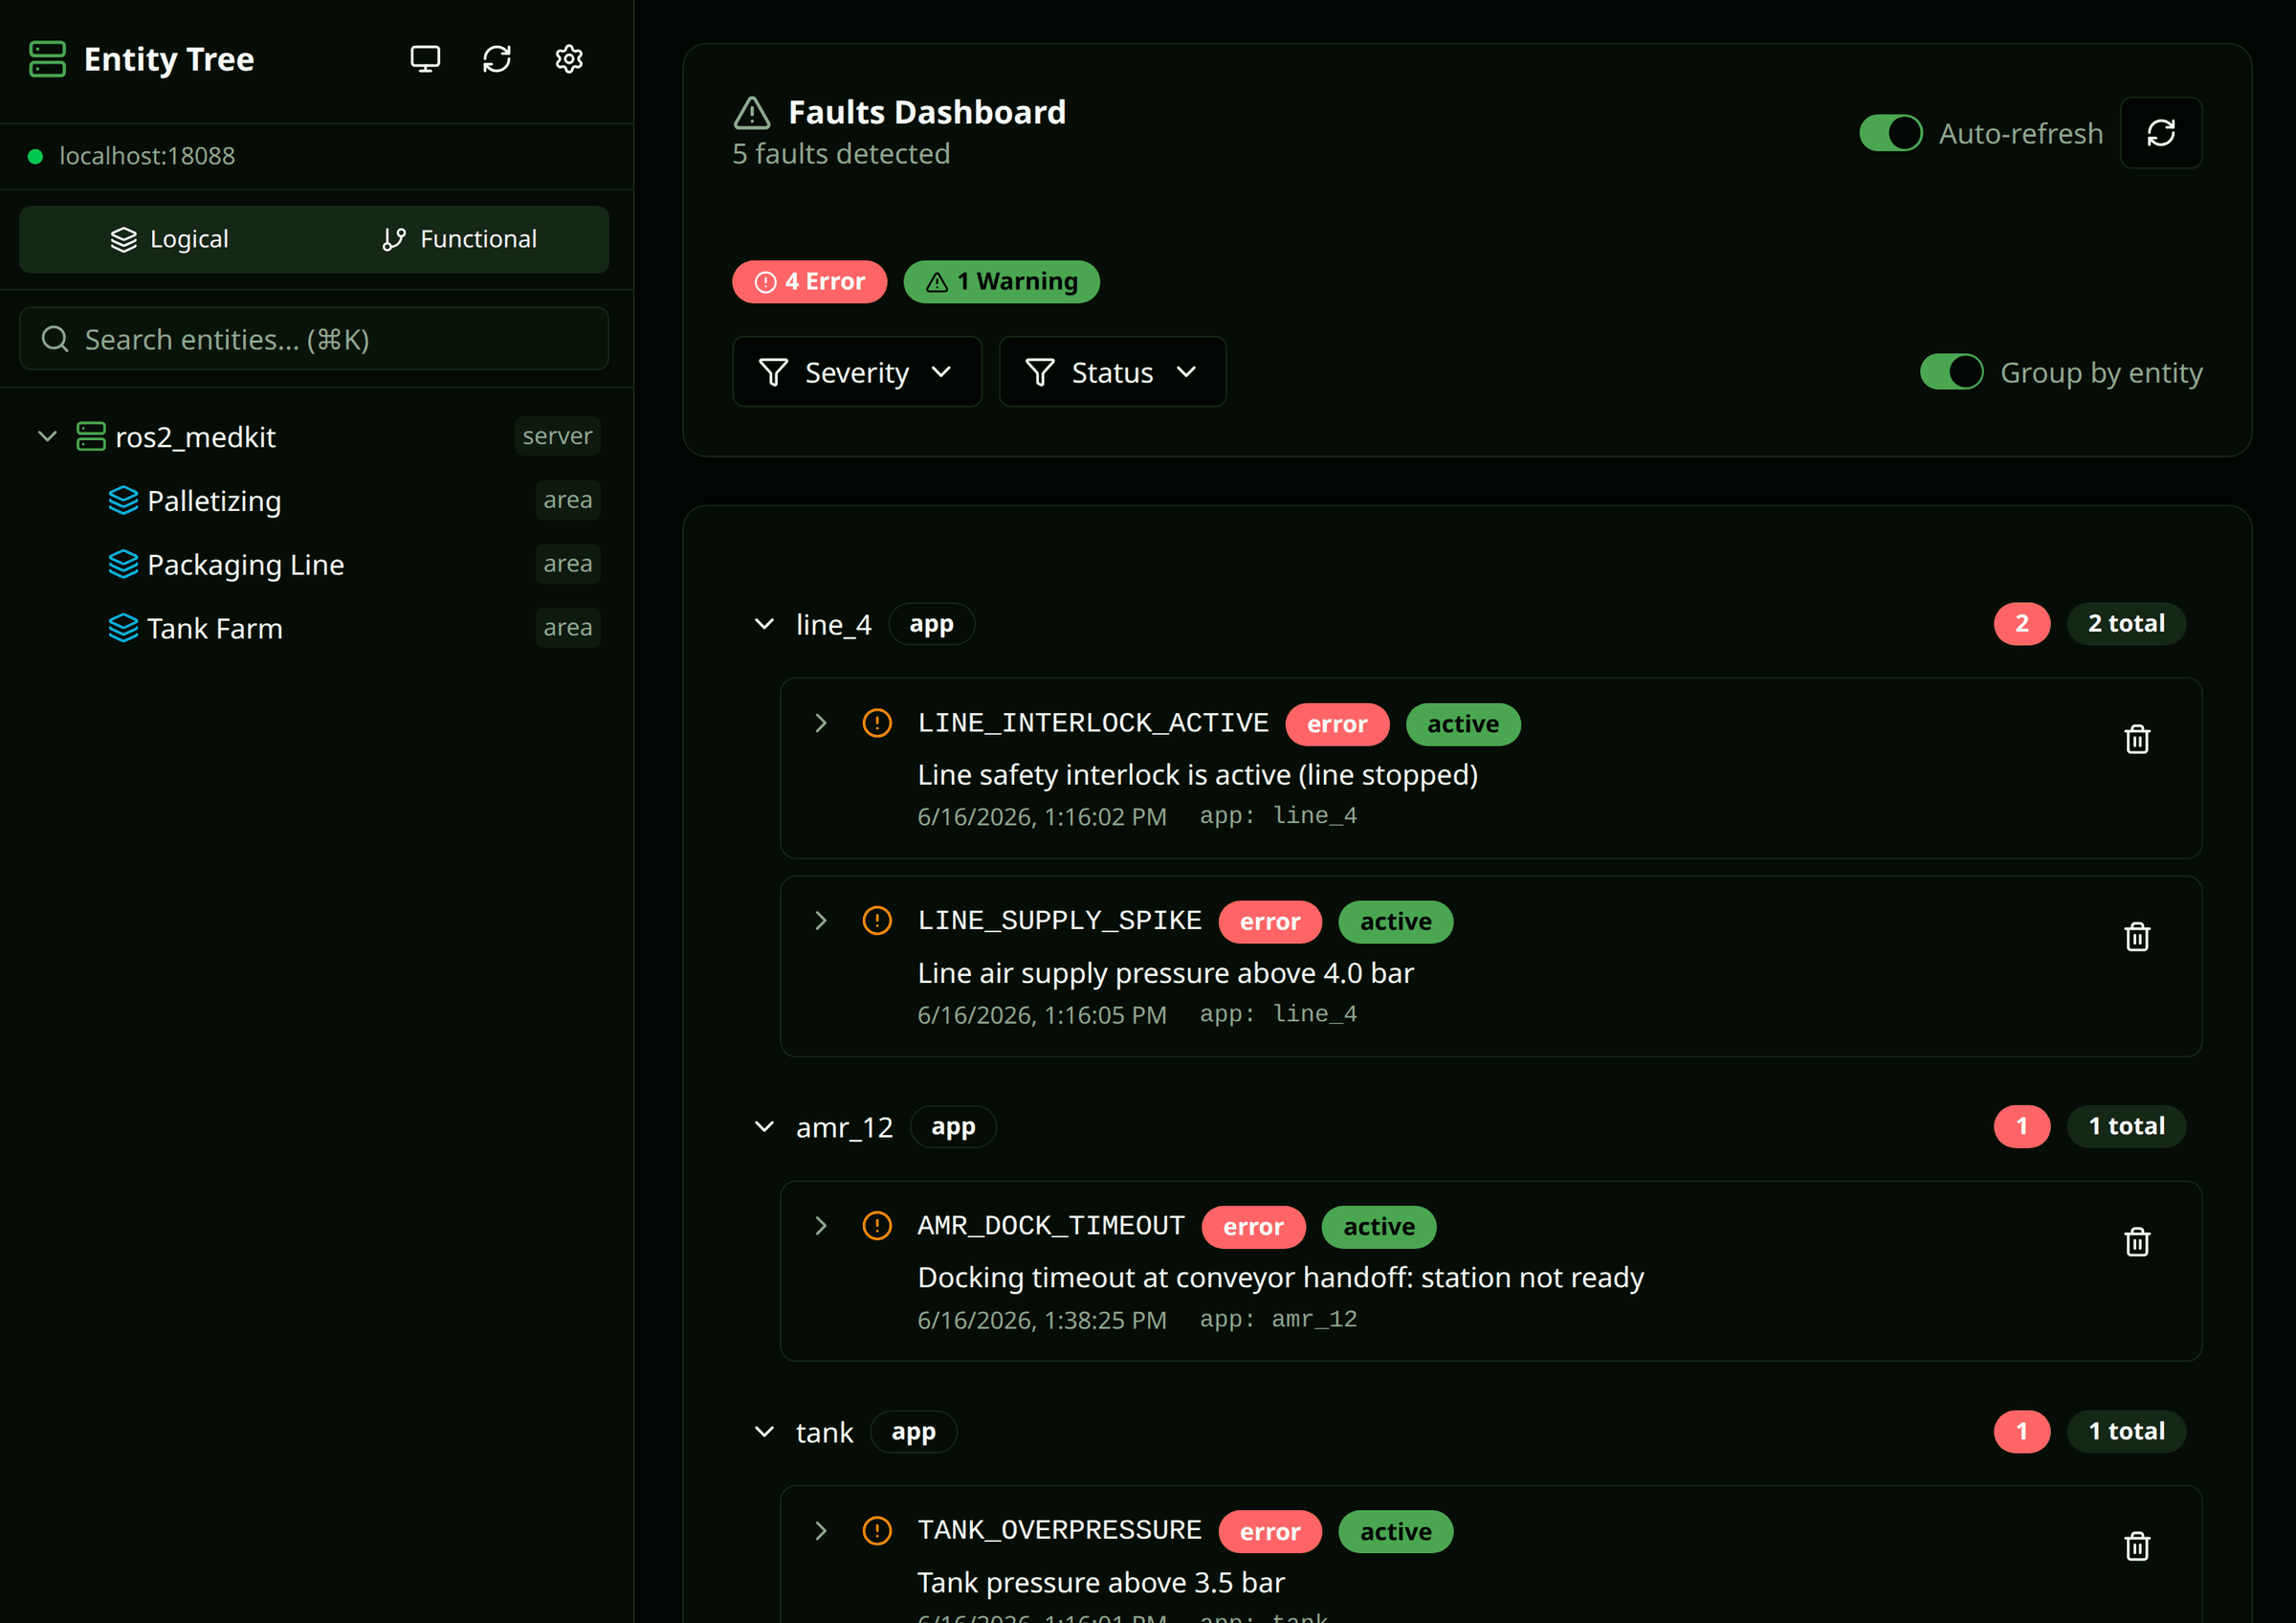
Every node behind one REST diagnostic API
A REST diagnostic API for your ROS 2 graph: discover nodes, read live data, trigger operations, manage configuration and faults. Apache 2.0, with a web UI and an MCP adapter.
Free, Apache 2.0 - shipped in the official ROS 2 distribution for Jazzy and Humble
Medkit
What changes for you
- One REST view of every node - faults, live data, operations, configuration - instead of SSH sessions and scattered scripts.
- New robot types onboard in days: the gateway discovers your graph, no per-robot glue code.
- Free and open source - evaluate on your real stack without procurement.
Key capabilities
- REST diagnostic API for every ROS 2 entity
- OPC-UA bridge for PLCs - one API across ROS 2 and the plant floor
- Discovery, faults, operations, configuration
- Web UI for browsing
- MCP adapter for AI agents
- Apache 2.0
Medkit
Where it fits
Medkit sits in front of your ROS 2 graph - and your PLCs over OPC-UA - as a standard SOVD (ISO 17978-3) diagnostic API. Open core, no lock-in.
ROS 2 graph
DDS
PLCs
OPC-UA
Medkit gateway
Open core, normalizes both
Web UI and MCP
Your tools and agents
Medkit
See it in action
Medkit
Free vs Pro
Medkit (open core)
- REST diagnostic API for ROS 2
- OPC-UA bridge for PLCs
- Discovery, faults, operations, configuration
- Web UI + MCP adapter
- Apache 2.0
Medkit Pro
- Every robot and PLC in one live fleet view
- Guided triage with proven fixes - about 40% faster to root cause
- Your AI wired into the same diagnostic context
- Signed, health-gated OTA with automatic rollback
- ECUs, safety runtimes, and custom protocols - one API
- Commercial support
Medkit
How to get it
Install from GitHub and point it at your ROS 2 graph - no license key, no registration, a working diagnostic plane the same day. Talk to us when you want protocol bridges, OTA, or guided triage on top.
Medkit on GitHubDeploy selfpatch on your fleet
Tell us your stack and we will show you which recurring faults it could fix today.